012026work in progress
osstrich
Open-source biped · sim-to-real locomotion
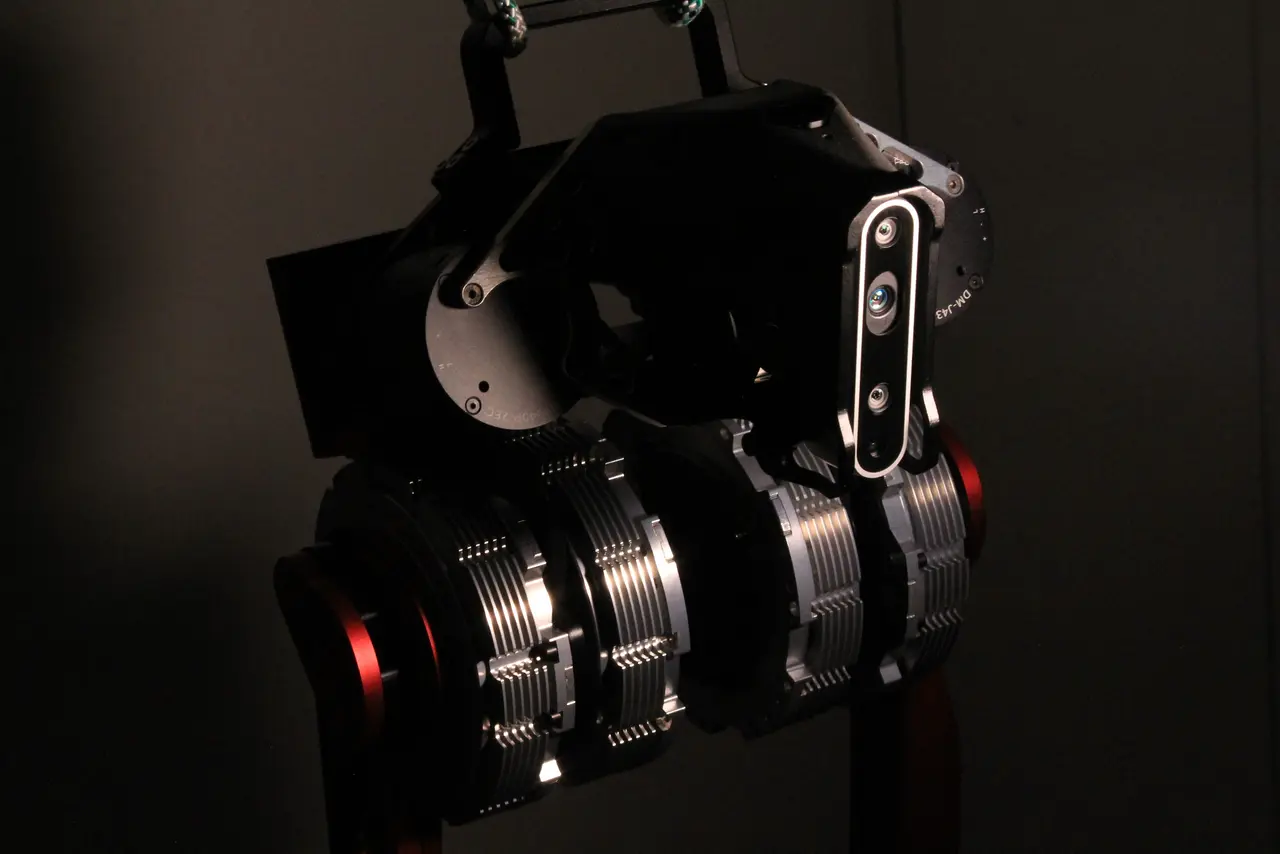
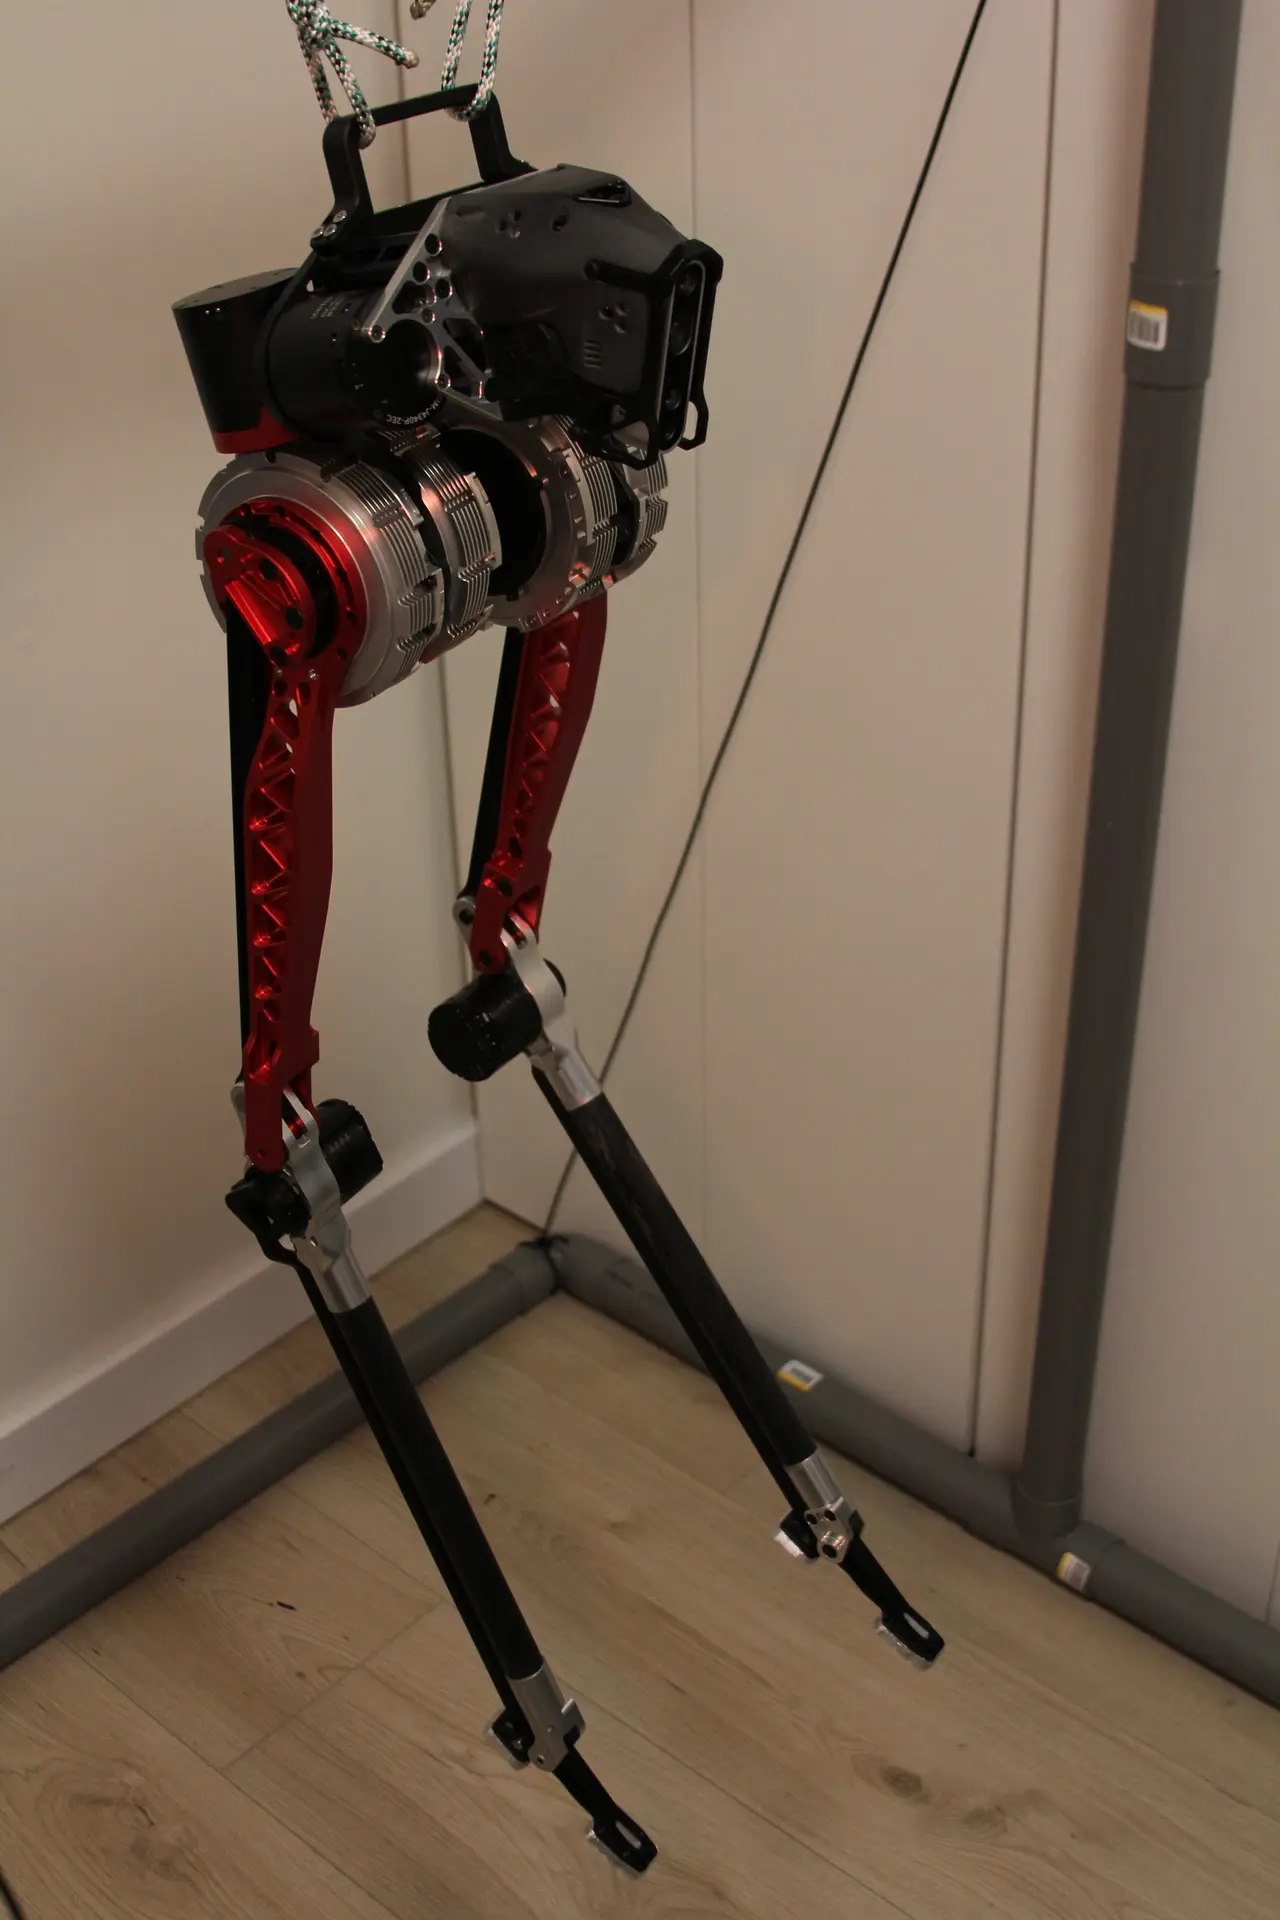
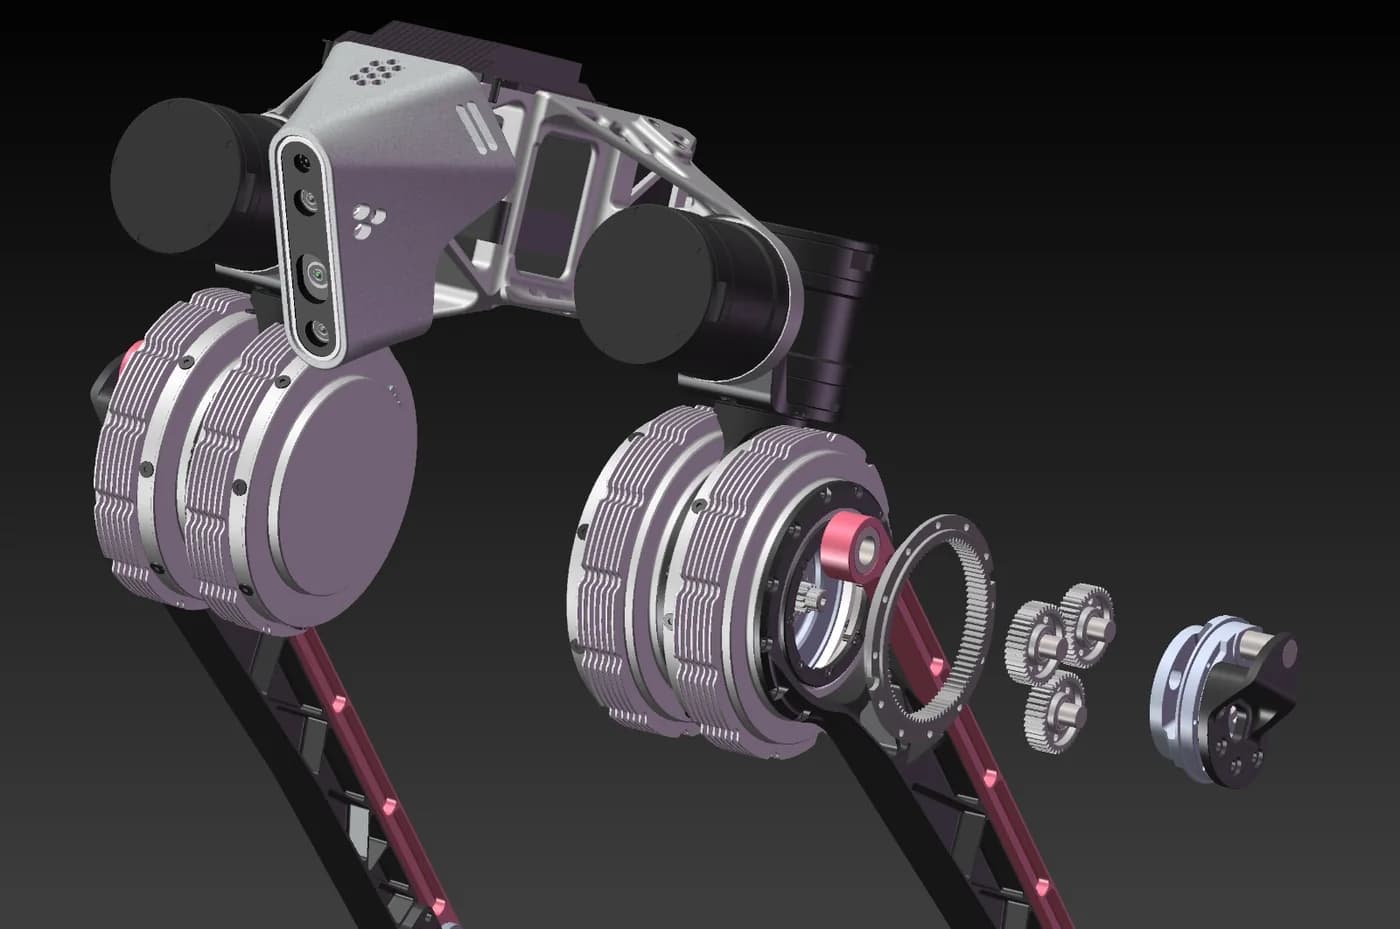
My friend Qihao Guo and I are building an open-source biped robot platform called osstrich. I'm developing the robot's high-level control and perception stack, including locomotion training, sim-to-real transfer, and vision. The first hardware prototype is built, and our reinforcement-learned policies already walk, climb stairs, and sprint at over 9 m/s in simulation. Our first milestone is to break the Guinness World Record for the world's fastest bipedal robot.
osstrich.com